
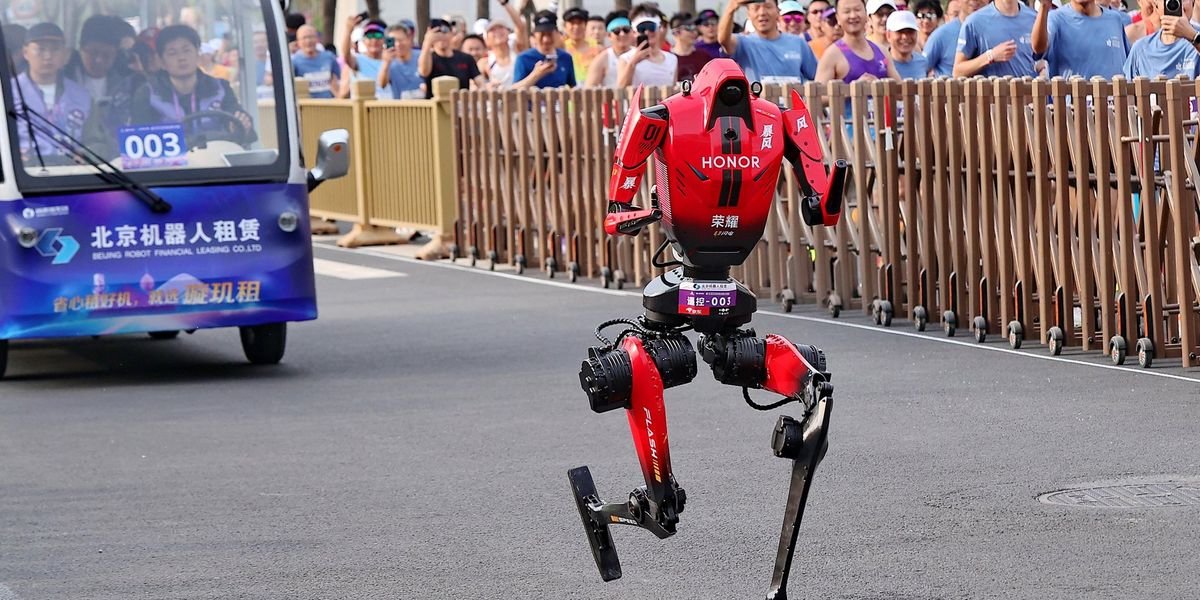
On April 19, 2026, the Honor Lightning humanoid robot ran a half-marathon in 50 minutes and 26 seconds, beating the human world report by 7 minutes and the very best robotic time from 2025 by nearly two hours.
How did they do it? Is there some magical know-how or method that unlocked this efficiency? How did they beat the considerably better-known Unitree (who reportedly needed to provide an ice backpack to try to full the race with out overheating)? My doctoral thesis concerned building and controlling hopping and running robots, and since then I’ve tried to design and build efficient commercial legged robots, giving me an honest concept of the constraints concerned. On this article, we check out the basic underlying constraints to try to reply these questions.
The Physics of Working
Running consists of alternating phases of a leg pushing in opposition to the bottom (“stance section”) and the physique flying by the air (“aerial section”). Within the aerial section, the physique falls because of gravity, shedding vertical momentum. The leg in stance section pushes in opposition to the bottom to redirect the vertical momentum upward, whereas the opposite leg swings ahead to reposition for the following foothold.
Electric motors use power to supply torque- the upper the torque, the extra power misplaced as warmth. Including a geartrain after the motor amplifies its torque and reduces its velocity. A big discount helps with torque manufacturing, however because the rotor of the motor itself has to spin quicker, it turns into very sluggish at accelerating its output. That is clearly unhealthy for the swing section described above. These competing results imply that for a specific motor, there’s normally a candy spot for the gear ratio:
The facility consumed by a robotic leg is minimized at an optimum gear ratio (30:1 on this instance).Avik De/Datawrapper
How Honor Did It
Whereas the Lightning’s motor specs usually are not revealed, the hip and knee motors roughly have a 110-150mm outer diameter. For an approximate set of motor parameters, I regarded to the ILM115x25 motor because of its related dimension and detailed specs.
We will use a easy physics mannequin to estimate the ability consumption for operating at 7 m/s (the Lightning’s common half marathon velocity) as gear ratio varies:
 The sunshine blue curve reveals the right way to decide the optimum gearing (45:1). The darkish blue curve reveals how a lot warmth might be produced within the knee motor, ~150W for the optimum gearing.Avik De/Datawrapper
We see that the drivetrain will not be magical: with a gear ratio chosen for this process (we’ll return to this beneath), the approximate robotic energy consumption can be a really affordable 400W.
Nonetheless, the dissipated knee energy ( usually the principle thermal limiting issue) is ~150W. That is nearly an unavoidable consequence — operating at human speeds with a humanoid-sized robotic will inevitably generate this quantity of warmth! Over a protracted interval, retaining the motor from overheating can be a problem, however the Lightning has a trick up its sleeve:
Based on Honor, the liquid – cooling pipes penetrate deep into the motors like capillaries. The excessive – energy liquid pump has a warmth – trade move charge of greater than 4 liters per minute. Every of the 4 drive motors within the decrease limbs is supplied with an unbiased liquid – cooling circuit.
Liquid cooling will not be new, but it surely’s undoubtedly not a commodity. It has proven up in analysis periodically, and on the business facet Apptronik tried it for a few of their prototypes however (to my data) doesn’t apply it to their major Apollo platform. Fundamental air convection-based cooling wouldn’t repeatedly have the ability to extract 150W out of the knee motor, and so the cooling know-how is a key enabler of one of these efficiency.
Why Others Couldn’t Compete
Why did Honor’s opponents, together with extra established and widely-shipped humanoids similar to from Unitree or Agibot, not compete as nicely?
We will use the identical mannequin to generate an equal energetics plot for strolling at 1.5 m/s, a way more modest however doubtlessly extra widespread exercise for a business humanoid robotic:
 The strong and dashed mild blue strains present a running-optimized design, whereas inexperienced strains present a walking-optimized design. The optimum ratio for strolling is way decrease (30:1 vs 45:1). Nonetheless, the ability dissipated within the knee motor whereas operating (darkish blue) is way larger at 30:1 vs 45:1—the value to pay for operating with a walking-optimized design.Avik De/Datawrapper
The plot provides a brand new inexperienced curve for the strolling energy, and the optimum gearing is considerably totally different!
Let’s say you design your robotic to excel on the regular strolling process and select the inexperienced design with 30:1 gearing. The knee motor energy to run a half marathon is over 300W (pink arrow), greater than 2x what we had with the running-optimized design. It wouldn’t be so stunning to want ice packs!
Conversely, visually following the inexperienced curve reveals that the running-optimized robotic wastes extra energy for strolling. Utilizing bigger motors sized for operating will increase the load of the robotic and wastes energy when it’s standing or strolling. The bigger motors additionally pose sensible points like bumping into objects whereas working in houses or factories.
Closing Ideas
Honor’s half marathon efficiency was a powerful engineering effort and consequence. It didn’t want any magical leaps in know-how, however the deployment of the capillary motor cooling resolution is a notable advance with out which this operating tempo would have been unsustainable. The cooling, weight optimization, and robustness advances might be helpful for extra sensible functions like carrying heavy payloads down the road.
 The Honor Lighting robotic [right] has a lot bigger motors driving its legs than the Unitree H1 robotic [left], making it a extra environment friendly runner however a much less environment friendly walker.Left: Wei Zhiyang/Zhejiang Day by day Press Group/VCG/Getty Pictures; Proper: VCG/Getty Pictures
Nonetheless, the Lightning will not be as well-suited to different duties as a robotic designed for better versatility. Engineering is all the time characterised by tradeoffs, and making the proper ones separates good merchandise from nice ones. With constantly enhancing AI language fashions, this very human talent is changing into probably the most precious one an engineer can have.
The information protection appeared to overly deal with the truth that the human half-marathon report had been damaged by a robotic. Machines and people have very totally different capabilities and constraints, so why ought to we ever have anticipated the half marathon time for a robotic and human to be associated? As in Deep Blue’s 1997 defeat of Garry Kasparov in chess, the place it couldn’t bodily transfer the items, the Honor robotic’s capabilities are a lot narrower than a human operating elbow-to-elbow with different runners whereas visually navigating the course with out GPS. Evaluating the robotic runner to a human runner is simply an apples-to-oranges comparability, and solely dangers diminishing Honor’s engineering achievement on one hand, and human athletic achievement on the opposite.
From Your Website Articles
Associated Articles Across the Net
